W-05
Robotics Team Pi
Software Engineer
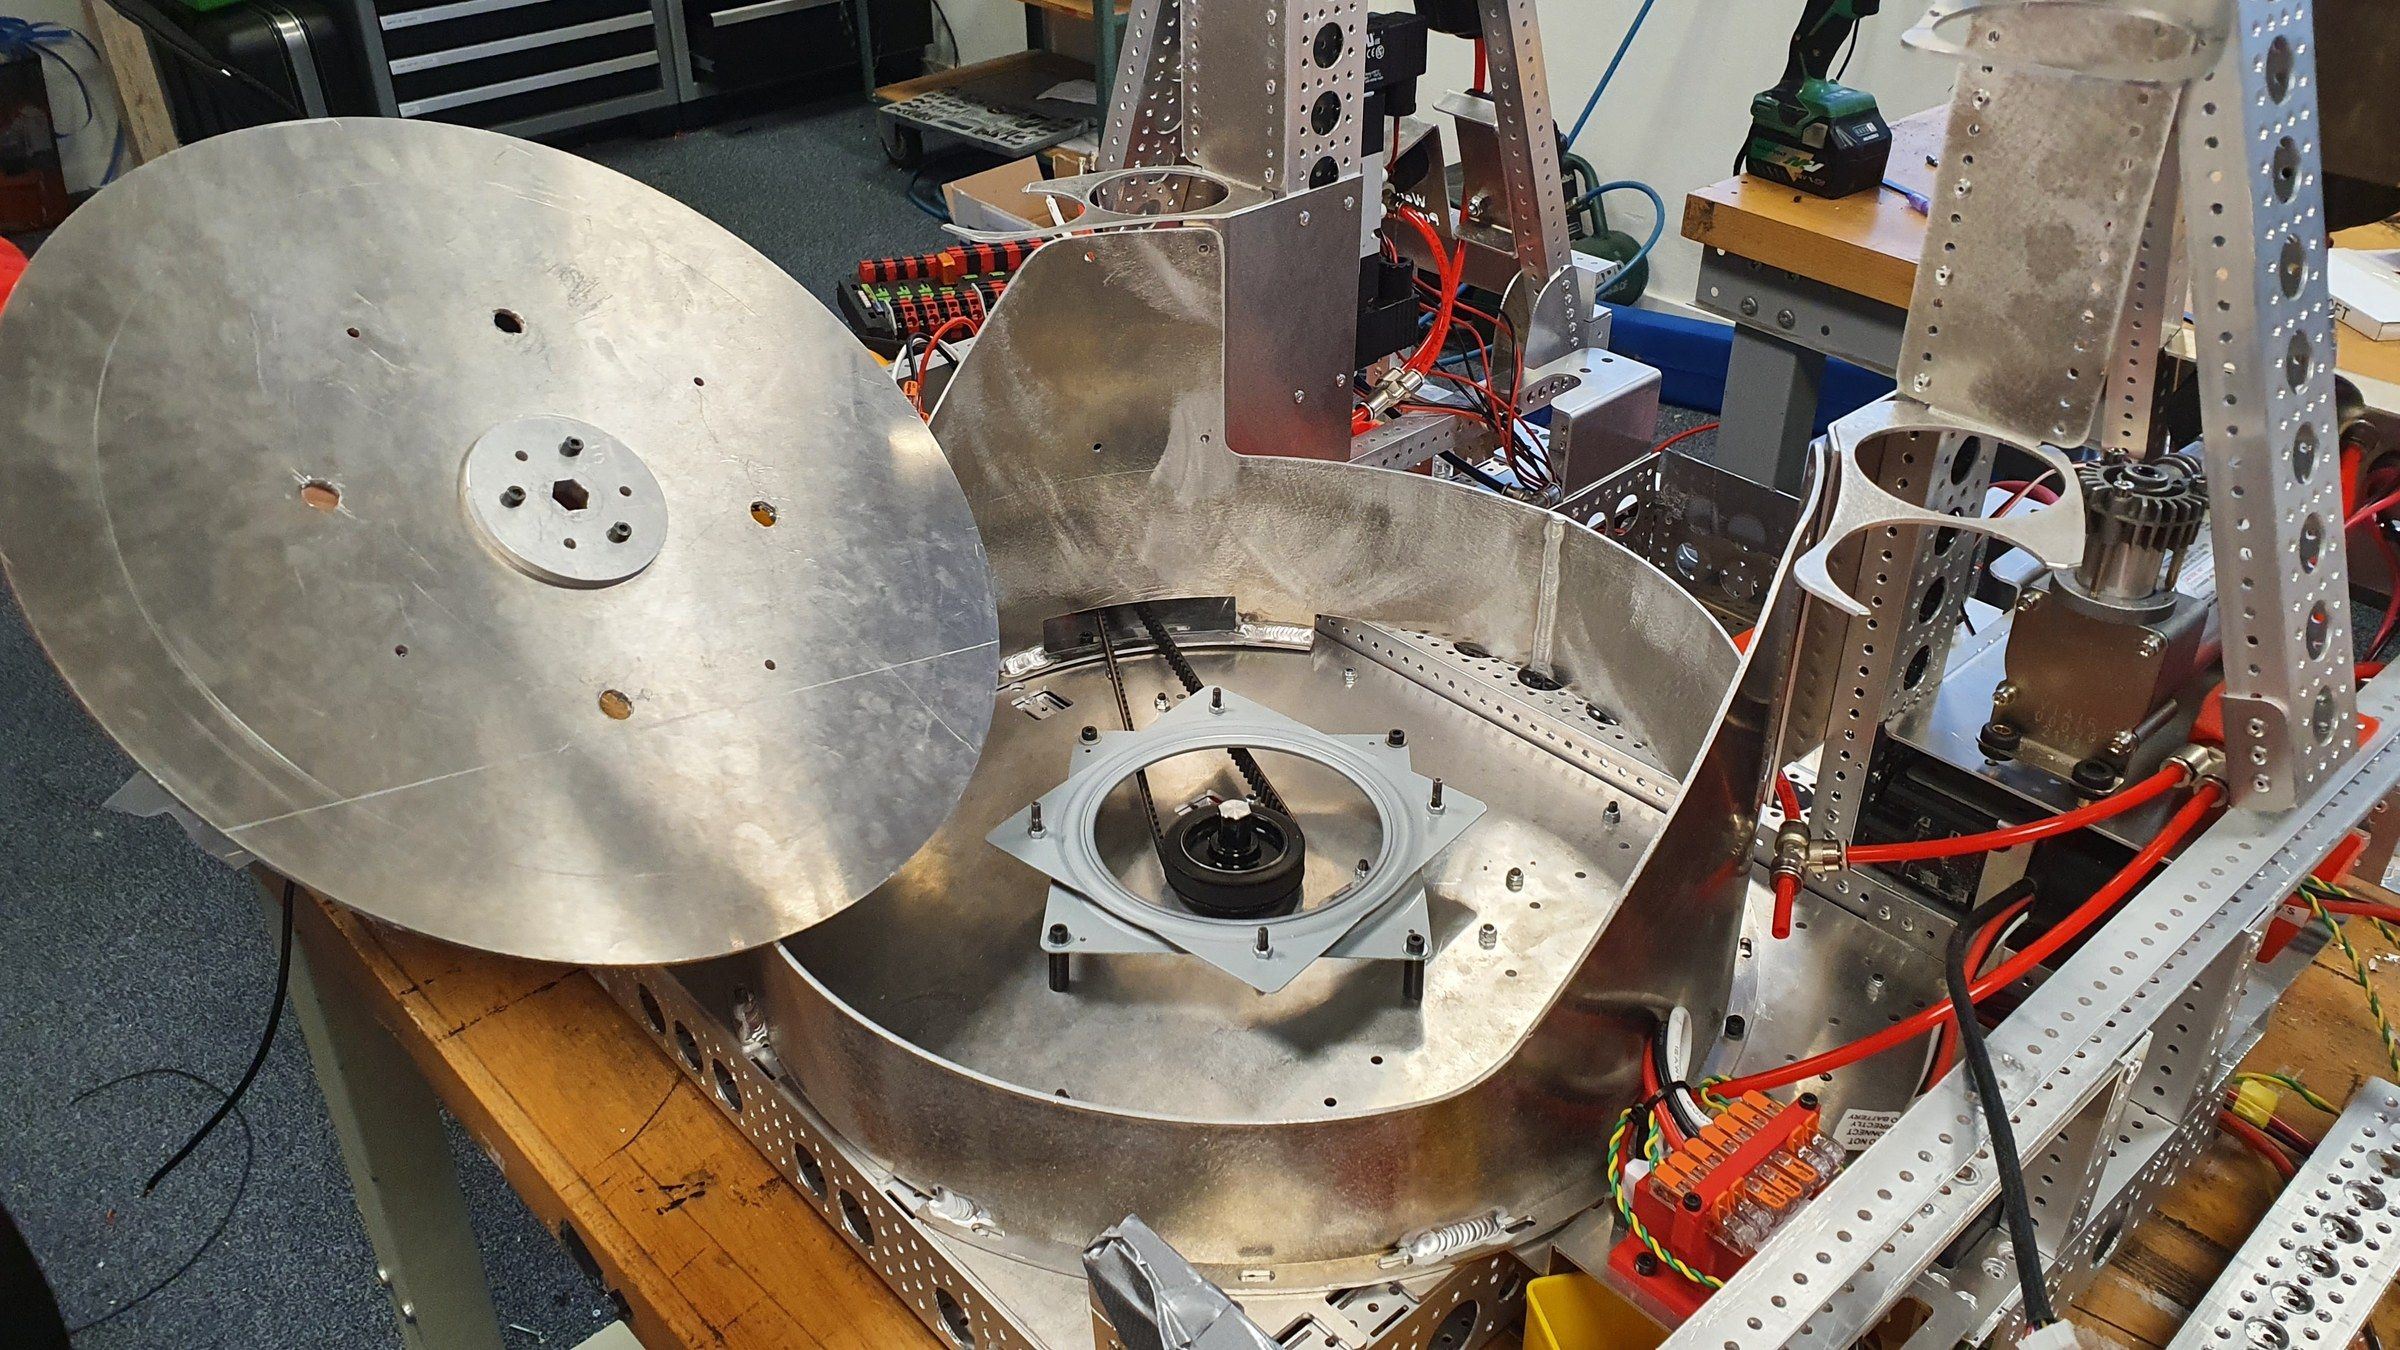
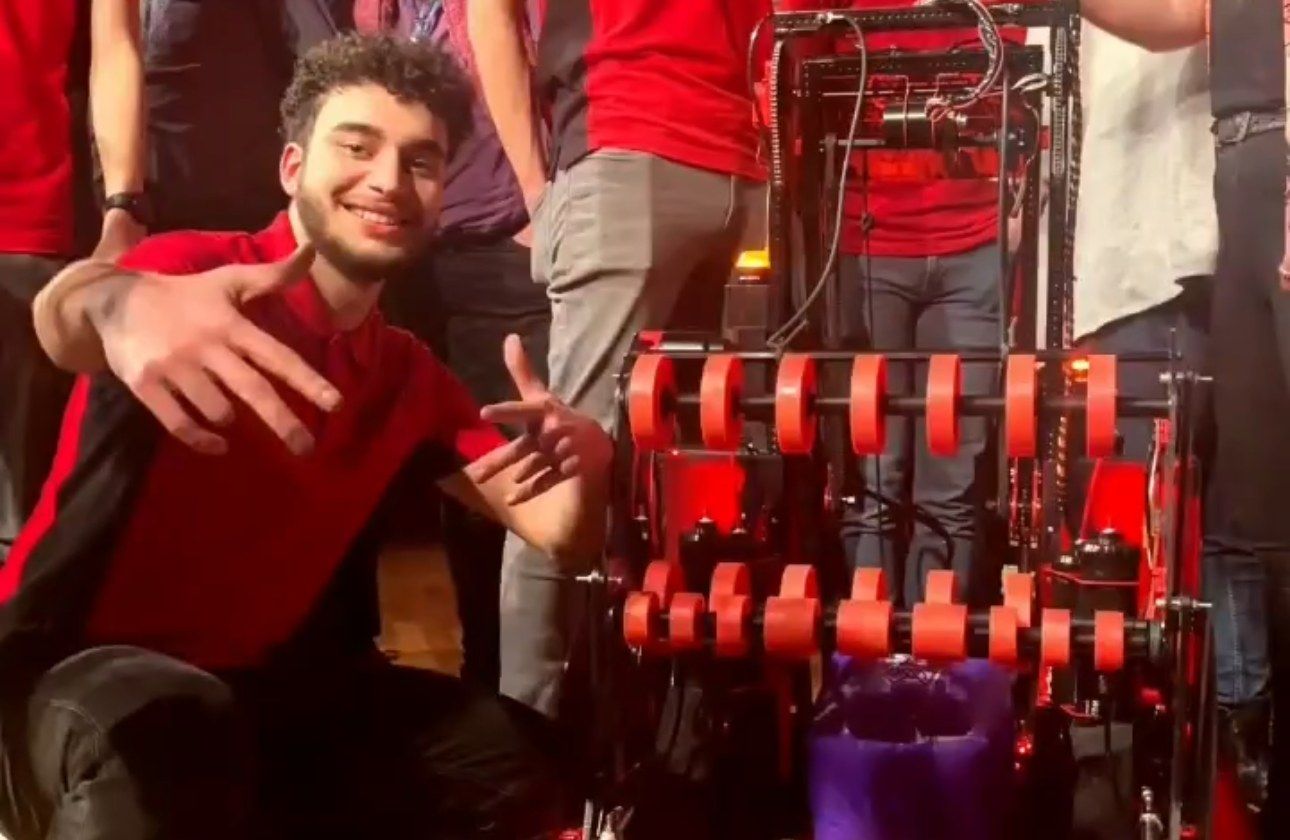
Robotics Team Pi is a student robotics team from Eindhoven that builds a new robot for competition every season.
I was one of two software engineers and designed the software architecture for that season’s robot, PHINIX.
- PHINIX
- 1 of 2 software engineers
- Python + OpenCV, depth camera
- 3rd, regional
Fig. 1 — How it fits together
02What I actually did
01 · Architecture
The full software architecture for PHINIX, drawn on a whiteboard first.
02 · Sensor comms
Getting every sensor talking to the rest of the robot.
03 · Vision
Object detection in Python and OpenCV with a depth camera.
04 · Competition
Third place at the regional competition.
PythonOpenCVDepth cameraArchitecture
03On the job